This section gives a combination of calculus, vectors, and parametric curves in an attempt to describe a
circle rolling along a parametric curve. The circles will have either a constant radius r or a variable
radius. Our circles will be tangent
to the base curve along which they are rolling in both versions, since this will make the rolling
appear closest to the actual physical process. In order to visualize this process, a vector format
for our curves and their tangents is necessary.
Let a parametric curve in the plane be defined by
\[
x = f(t) \qquad\mbox{and}\qquad y = g(t) ,
\]
with t in the interval [𝑎, 𝑏].
Its vector format is x(t) = (f(t), g(t)). This is called the
position vector field of the parametric curve. Its derivative vector field or tangent vector
field is
Also, N(t) can be made length r, corresponding to the radius of our circles, by first
making it a
unit vector field and then multiplying by r. Then the center vector field C(t) for our
circles is
given by
Here is an interactive Python script designed to give you an intuitive experience. It allows you to slide a
parameter control t
along the interval [𝑎, 𝑏]
and watch the position vector x(t), the tangent vector T(t), the normal vector
N(t), and your generated rolling circle tracking dynamically along the curve.
Figure 1.0: Illustration of formula (1).
If we now write C(t) = (h(t), k(t)), then our rolling circles are
given by the parametric curve:
\begin{align*}
\left( x(s) , y(s) \right) &= \left( r\,\cos s + h(t) , r\,\sin s + k(t) \right)
\\
&= r \left( \cos (s) , \sin (s) \right) + \mathbf{C} (t) .
\end{align*}
As s varies in the interval [0, 2π], we move around this circle while we get one circle for each
fixed value t ∈ [𝑎, 𝑏]. In this situation, s is the variable that moves us around each
circle while t
is the rolling variable that moves us from one circle to the next circle because it controls the location of the
circles’ centers.
The formula for C(t) in \eqref{EqCircle.1} may appear complicated; however, if we take a minute
to examine each piece, we should begin to see how simple it really is. Since C(t) is the center
of the
circle that we wish to roll along the curve, we need to start on the curve, x(t) and move
r units
perpendicular to x(t). Since N(t) is orthogonal to T(t), which in turn is
tangent to x(t) we have
that N(t) is orthogonal to x(t). To proceed r units in the N(t)
direction, we must first make N(t)
unit length by dividing it by its magnitude, then multiplying it by r. This gives the second piece of
the sum found in Eq.\eqref{EqCircle.1}.
Example 1:
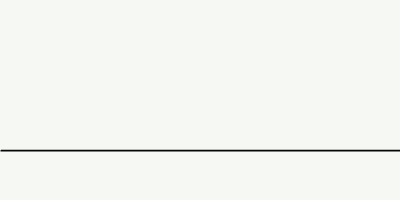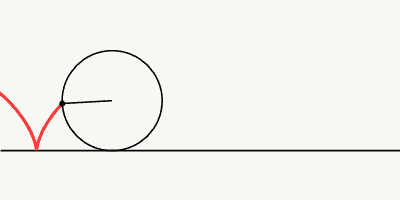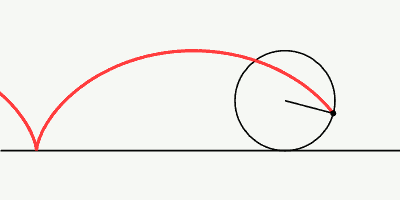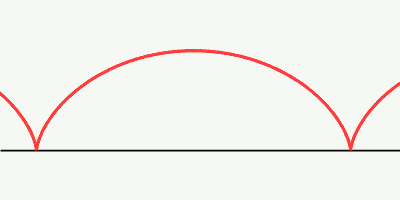
A cycloid is the geometric curve traced by a single
point on the rim of a circle as it rolls along a straight line without slipping. Often called the "Helen of
Geometers" due to the frequent historic quarrels it sparked among mathematicians, this shape possesses unique
properties that solve legendary problems in physics and calculus.
Figure 1.1: Cycloid.
The base curve is simple in our case---it is just a horizontal line:
\[
x = t \qquad \mbox{and} \qquad y = 0 .
\]
Then the normal vector at every point x = t remains the same and it is collinear with the
ordinate axis.
Let a circle of radius r
roll along the flat x-axis. We place the origin (0,0)
at the point where our tracing point P
initially touches the ground.
Let the circle rotate through an angle θ
(in radians). As the circle rolls:
The center of the circle C
moves horizontally. Because it rolls without slipping, the horizontal distance the center travels is
exactly equal to the arc length rolled, which is
rθ.
The coordinates of the center C
at any angle θ
are (rθ, r).
Now, we find the position of the tracing point P(x, y)
relative to the moving center C. When the circle rotates clockwise by an angle θ:
The point P rotates backward relative to the center.
Measuring from the lowest point of the circle (the contact point), the vector from the center C
to the point P
points downward and backward.
Figure 1.2: Horizontal displacement QP (in blue).
Using standard trigonometry from the center C:
The relative horizontal displacement is −r sinθ (see right triangle ▲CQP with angle
∡C = θ in Figure 1.2).
The relative vertical displacement CQ is −r cosθ.
Combining the absolute position of the center C
with the relative position of P:
\[
\begin{split}
x &= x_C + \Delta x = r\theta - r\,\sin\theta , \\
y &= y_C + \Delta y = r - r\,\cos\theta .
\end{split}
\]
Factoring out r
gives the standard parametric equations of a cycloid:
Cusps: The curve touches the flat baseline (y = 0) at periodic intervals where θ =
2πn, independently of the radius r.
Peaks: The maximum height of the curve is 2r, occurring at θ = π, 3π, ….
Applications: The cycloid solves both the brachistochrone problem (the path of fastest descent under
gravity) and the tautochrone problem (where the time taken by an object sliding down the curve is
independent of its starting point).
To find the distance the tracing point actually travels during one full rotation (0 to 2π), we use the
parametric arc length formula:
The total length of one arch is exactly 8
times the radius of the rolling circle.
How to use this code: Click on the Evaluate button to run the code. It will generate a looping GIF of the
cycloid animation and embed it via base64 HTML. The code uses pure Python with numpy, matplotlib, and Pillow,
without any ipywidgets or JavaScript.
■
End of Example 1
Example 2:
An epicycloid is a plane curve made by tracking
the path of a chosen point on the edge of a circle as it rolls around the outside of another fixed circle
without slipping.
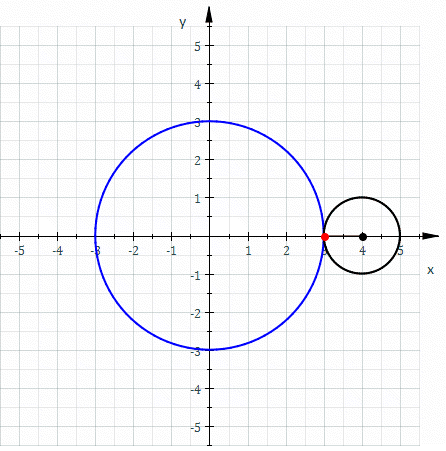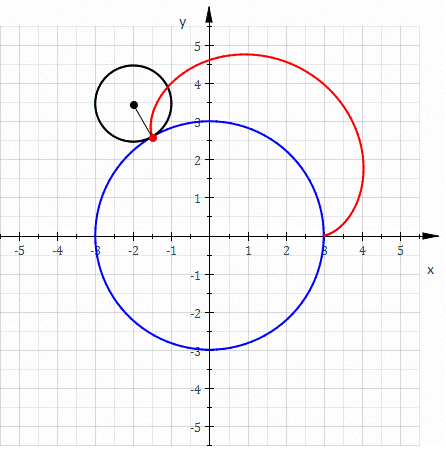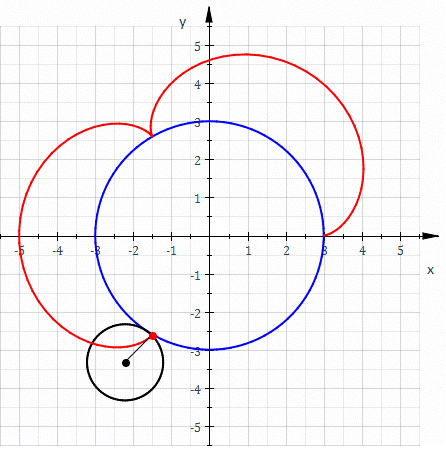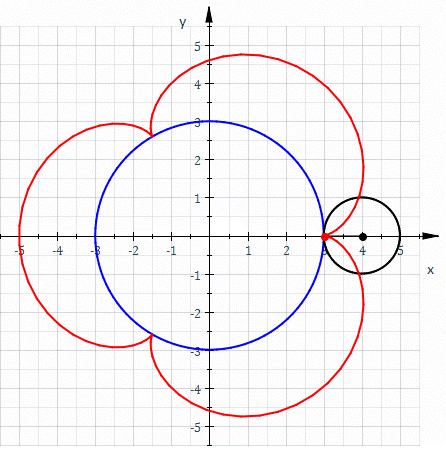
Figure 2.1: Epicycloid.
Let a stationary base circle have a radius of R centered at the origin (0,0). A smaller rolling
circle with a radius of r rolls along its outer circumference without slipping.
We trace a point P starting on the outer rim where the two circles touch on the positive x-axis. As
the rolling circle moves through an angle θ around the center of the base circle:
The center C(xc, yc) of the moving circle is located at a
distance of R + r from the origin. Its coordinates are:
\[
x_c = \left( R + r \right) \cos\theta , \qquad y_c = \left( R + r \right) \sin\theta .
\]
Because it rolls without slipping, the arc length traveled on both circles must be equal (Rθ =
rα, where α is the internal rotation angle of the rolling circle). The position of
P(x, y) relative to the center C(xc, yc)
depends on the total accumulated angle of rotation of the rolling radius, which is
To understand how the latter formula connecting ϕ and θ is derived, we need to look
closely at the condition for rolling without slipping and track the angles from two different points of
view: an observer standing outside the system (the fixed base frame) and the moving center C of the
rolling circle.
Let’s set up the system with a large stationary base circle of radius R
centered at the origin, and a smaller circle of radius r
rolling along its outside edge.
θ: The angle of the center of the rolling circle relative to the origin. This is how far the small
circle has traveled around the large circle.
The point of contact on the large circle has traveled an arc length of:
\[
s_{\mbox{base}} = R\,\theta .
\]
Because the small circle rolls without slipping, the length of the arc it has rolled out along its own
circumference must be exactly equal to the distance it covered on the large base circle.
If we let α
be the angle that the small circle has rotated relative to the moving line connecting the two centers, its
internal arc length is: srolling = rα.
The angle α
only measures how much the circle has spun relative to the line connecting the centers. However, that center
line itself is also rotating around the origin at an angle of θ.
To find the total, absolute rotation angle ϕ
of the tracking point relative to the fixed horizontal x-axis (the base frame), we have to add
these two rotations together:
Combining the moving center coordinates with the trigonometric rotation adjustments gives the parametric
equations for an epicycloid:
\[
\begin{split}
x (\theta ) &= \left( R + r \right) \cos\theta - r\,\cos \left( \frac{R+r}{r}\,\theta \right) ,
\\
y (\theta ) &= \left( R + r \right) \sin\theta - r\,\sin \left( \frac{R+r}{r}\,\theta \right) .
\end{split}
\]
The following Python code creates a cardioid (a heart-shaped epicycloid) by setting R =
2 and r = 1 (a 2:1 ratio). You can easily change these parameters at the top of the script to create
different shapes (e.g., setting R = 2, r = 0.5 creates a nephroid).
To clarify the geometry first: an epicycloid with R = r
creates a cardioid (1 cusp), while an epicycloid with R = 2r
creates a nephroid (2 cusps).
Below are two options for Wolfram Mathematica code. The first plots both curves statically side-by-side,
and the second creates an interactive animation showing the transition from the cardioid to the R =
2r
curve.
This code let you smoothly change the value of R
from r
(cardioid) to 2r, showing exactly how the shape transforms.
How to use this code: Click on the Evaluate button to run the code. It will generate an interactive slider
that allows you to smoothly change the value of R from r (cardioid) to 2r, showing
exactly how the shape transforms.
Figure 2.6: Cardioid (R = r).
■
End of Example 2
Example 3:
An ellipse centered at the origin (0,0)
with a horizontal semi-major axis 𝑎
and a vertical semi-minor axis b
is defined parametrically by the following two equations:
is the incomplete Elliptic integral of the second kind with parameter k. In Python, it
can be evaluated as
Now we roll a unit circle (of radius 1) counterclockwise along the ellipse with making point on its
circumferance. To accurately model a circle rolling without slipping along the ellipse perimeter, the rotation
angle must be proportional to the actual distance traveled along the curve—which is the arc length governed by
the incomplete elliptic integral of the second kind.
Figure 3.5: A circle rolling Ellipse.
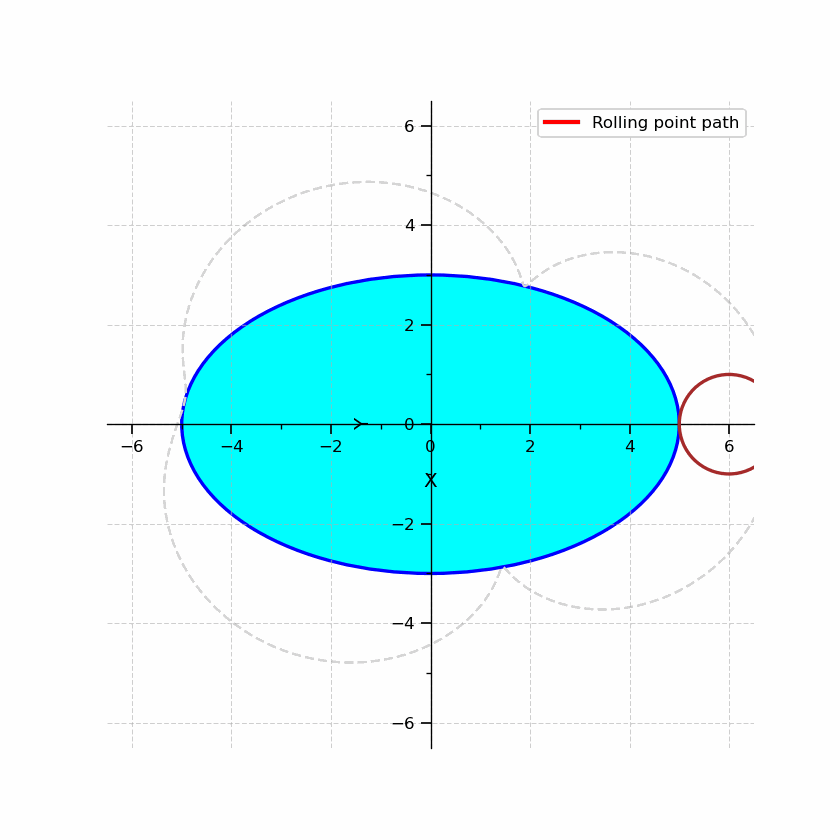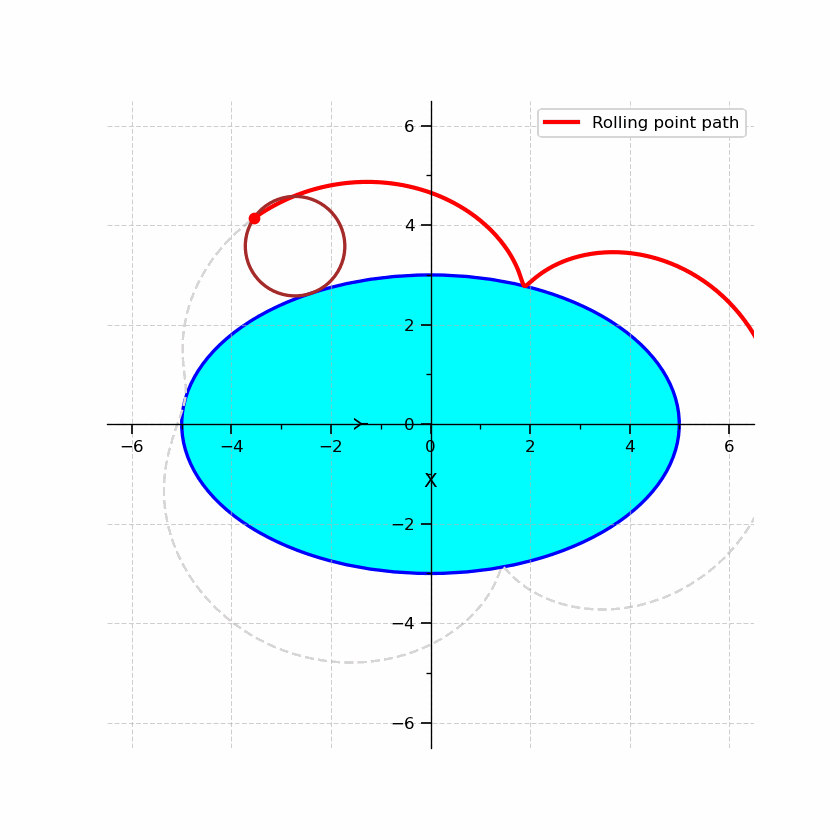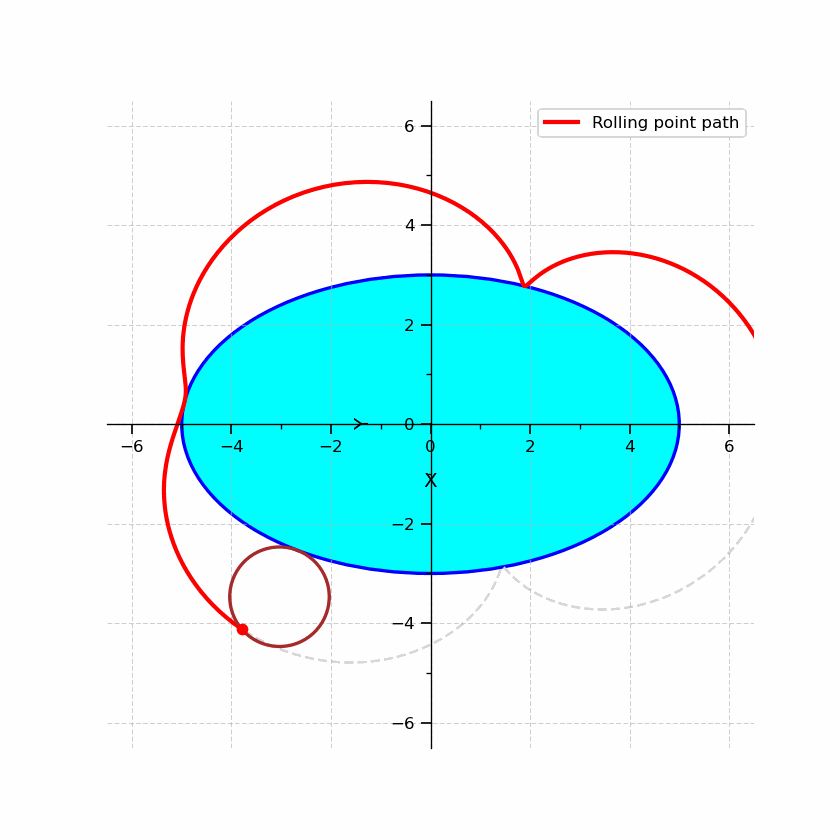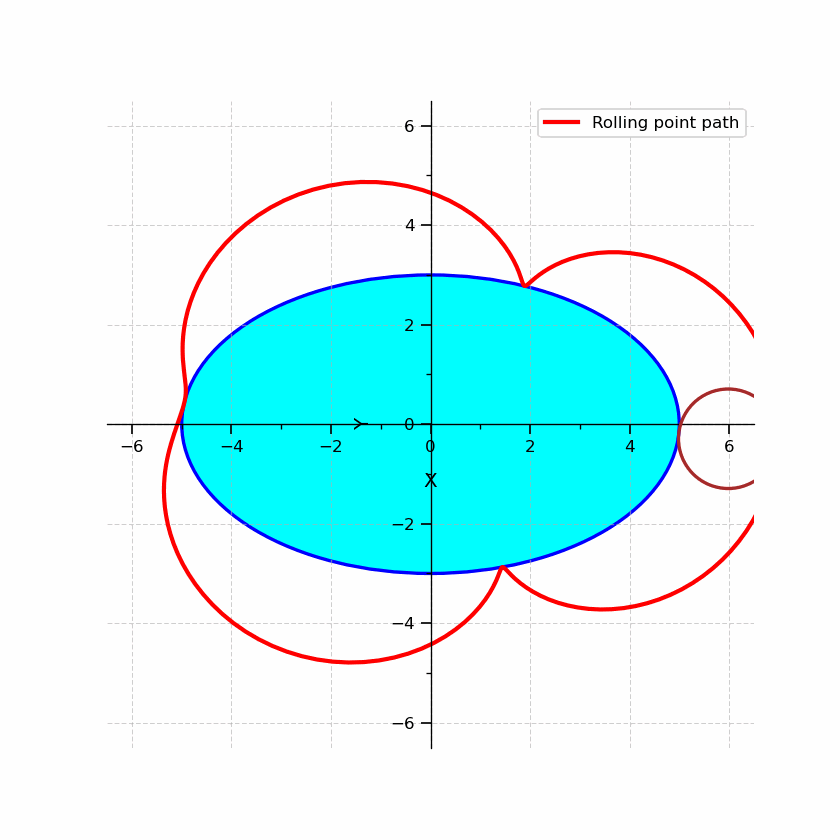
We want to add a trace line to the plot that shows the continuous path the red dot/point carves out as it
rolls all the way around.
While a unit circle rolls around the ellipse, the red dots will trace a physically accurate cycloid-like
progression that reflects the true geometry of the ellipse.
Figure 3.6: A cycloid-like curve formed by rolling circle.
■
End of Example 3
Example 4:
We choose the base parametric curve as y = 2 cos(x). This curve can be paratmetrized as
\[
x = t, \qquad y = 2\,\cos (t) , \qquad t \in [0, 2\pi ] ,
\]
Next, we use the Manipulate command to create an animation of these circles “rolling” along the cosine curven.
The arc length s(t) from τ = 0 to τ = t is given by the integral
The elliptic integral of the second kind is implemented in the Wolfram Language as EllipticE[phi, m] (note the
use of the parameter m = k² instead of the modulus k).
Manipulate[
Module[{basePoint, normalVect, circleCenter, currentArc, rollAngle, redPoint},
(* 1. Position on the cosine curve *)
basePoint = {tval, 2 * Cos[tval]};
(* 2. Upward unit normal vector to the cosine curve *)
normalVect = {2 * Sin[tval], 1} / Sqrt[1 + 4 * Sin[tval]^2];
(* 3. Exact center of the rolling circle *)
circleCenter = basePoint + r * normalVect;
(* 4. True arc length of y = 2*Cos[t] from 0 to tval *)
currentArc = EllipticE[tval, -4];
(* 5. Clockwise rotation angle based on distance traveled *)
rollAngle = -currentArc / r;
(* 6. Position of the red marker point on the circle's edge *)
redPoint = circleCenter + r * {Cos[rollAngle], Sin[rollAngle]};
Graphics[{
(* A. Draw the baseline Cosine Curve *)
Thick, Blue, Line[Table[{x, 2 * Cos[x]}, {x, -1, 7, 0.05}]],
(* B. Draw the rolling circle *)
Brown, Thick, Circle[circleCenter, r],
(* C. Draw a radius line to visually show the circle spinning *)
Darker[Gray], Line[{circleCenter, redPoint}],
(* D. Mark the center point with a red '+' *)
Red, Thick, Text["+", circleCenter],
(* E. Draw the red marker point on the circumference *)
Red, Disk[redPoint, 0.05]
},
Axes -> True,
GridLines -> Automatic,
PlotRange -> {{-1, 7}, {-3, 3.5}},
AspectRatio -> Automatic
]
],
(* Control Slider Settings *)
{{tval, 0, "Location (t)"}, 0, 2 * Pi, Pi / 64},
(* Define the radius globally upon initialization *)
Initialization :> (r = 0.2;)
]
■
End of Example 4
Example 5:
We modify the calculations given in the previous example with a nonconstant radius. In particular, we are
going to choose the radius to be 1/κ, where κ is the curvature of the function.
Curvature is denoted by the Greek letter kappa and is defined as the magnitude of the rate of change of the
unit tangent vector with respect to arc length.
Curvature is inversely proportional to the radius of the
"osculating circle" (the circle that best hugs the curve at that specific point).
For a regular planar curve given by y = f(x), the curvature
κ at any point x
is calculated using its first and second derivatives:
If we
fix a point on our graph and compute its curvature κ and draw a circle with radius 1/κ touching
the function at that point, in essence, we have created a circle of best fit for the function at that
specified point. This also implies that the circle should always lie on the concave-in side of the
function and should have the same tangent line at the point. A circle that satisfies these criteria
is sometimes referred to as an osculating circle.
For 2D curve r(t) = (x(t), y(t), we compute the unit tangent
vector defined as
It may not be immediately obvious, but the unit tangent vector and its derivative are orthogonal.
We could actually compute the dot product between the expressions given in (5.1) and (5.2),
or we could make the following observation: Since T(t) is a unit vector, its length
|T(t)| = 1 for all t; the
derivative of the magnitude of T(t) must be zero:
Archimedes (c. 287 – c. 212 BC) is celebrated as the supreme mathematical and physical genius of antiquity.
Operating with cumbersome Greek numerals and limited prior tools, he single-handedly derived foundational
concepts for calculus, mechanics, and geometry.
The Archimedean spiral (also known as
Archimedes' spiral, the arithmetic spiral) is a spiral curve described in polar coordinates by the equation
r = 𝑎 + bθ. In Cartesian coordinates (x, y), the parametric
equations with respect to the parameter θ
(the angle of rotation in radians) are:
\[
x (\theta ) = \left( a + b\theta \right) \cos\theta , \qquad y (\theta ) = \left( a + b\theta \right)
\sin\theta .
\]
An Archimedes' spiral appears on Jacob Bernoulli's
tombstone due to a mason's mistake, as Bernoulli actually requested a logarithmic spiral because he viewed its
self-similar properties as a metaphor for life after death and the Latin motto "Eadem mutata resurgo"
("Although changed, I shall arise the same").
(* Set parameters: starts at origin (a=0), turns expand by b=0.1 *)
a = 0;
b = 0.1;
ParametricPlot[
{(a + b*t) * Cos[t], (a + b*t) * Sin[t]},
{t, 0, 6 Pi}, (* 6 Pi gives exactly 3 full turns *)
PlotStyle -> Directive[Thick, Darker[Green]],
PlotLabel -> "Archimedes' Spiral",
Axes -> True
]
Figure 5.1: Archimedean spiral.
There are know some otehr spiral curves.
Logarithmic Spiral (Equiangular Spiral) expands exponentially, meaning its shape stays identical as it
grows (self-similarity). The logarithmic spiral was first described by René Descartes in 1638. Its equation in
polar is
Fermat's Spiral (Parabolic Spiral) shares a close relationship with the Archimedean spiral but expands
much more slowly because the radius depends on the square root of the angle.
Hyperbolic Spiral (Reciprocal Spiral) acts as the inverse of an Archimedes' spiral. Instead of moving
outward as the angle increases, it starts infinitely far away and winds inward toward the origin.
Clothoid (Euler Spiral / Cornu Spiral) is defined by a fundamental geometric property: its curvature
increases linearly with its arc length.
This means as you travel along the curve, it turns tighter and tighter at a perfectly constant rate. The
cleanest definition of the Euler spiral is given by its intrinsic equation, which relates its curvature
(κ) directly to its arc length (s):
\[
\kappa = \frac{s}{a^2} .
\]
In Cartesian coordinates (x, y), we integrate the intrinsic property. This yields equations
defined by the Fresnel Integrals:
\[
s (t) = a \int_0^t \,\cos \left( \frac{u^2}{2} \right) {\text d}u , \qquad y(t) = a \int_0^t \,\sin
\left( \frac{u^2}{2} \right) {\text d}u .
\]
Now we plot the Archimedes' spiral along with the four osculating (touching) circles at the exact specified
points. Every circle has the radius 1/κ(θ). The code automatically uses vector calculus to
determine the exact radius of curvature and the center C coordinates for each circle.